Skip to main content
Main navigation
Home
Autonomous Navigation
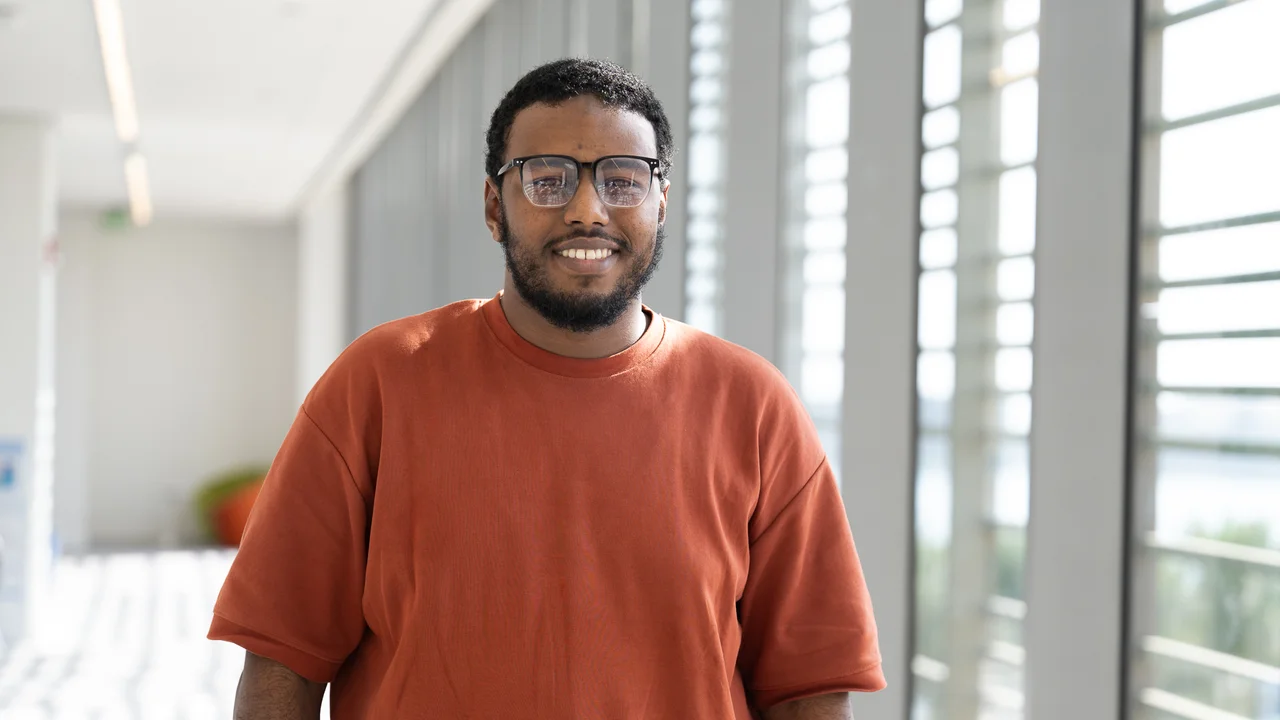
Abdelgabar Ahmed
Ph.D. Student,
Electrical and Computer Engineering
Autonomous Navigation
GNSS localization
Sensor Fusion
Working on robust urban localization by fusing GNSS, vision, and inertial sensors to mitigate multipath effects. Developing theoretical performance bounds on GNSS localizability using spatial statistical models of satellite geometry and signal availability.